Connect to Devices coBridge
coBridge is an open-source edge software provided by coScene, currently supporting ros1 noetic, ros2 foxy and humble versions. coBridge runs as a ros node on the robot side and interacts with the cloud through websocket connections. After establishing a connection with the cloud, coBridge can subscribe to ros topics and call ros services based on cloud commands, enabling real-time robot status monitoring, remote command deployment, and other functionalities.
Prepare coBridge
Please refer to Install coScene Software Using APT to install coBridge. Launch the ROS node afterwards.
  source /opt/ros/${ROS_DISTRO}/setup.bash

  # for ros 1 distribution
  roslaunch cobridge cobridge.launch

  # for ros 2 distribution
  ros2 launch cobridge cobridge_launch.xml
Real-time Device Visualization Using coStudio
- Download coStudio.
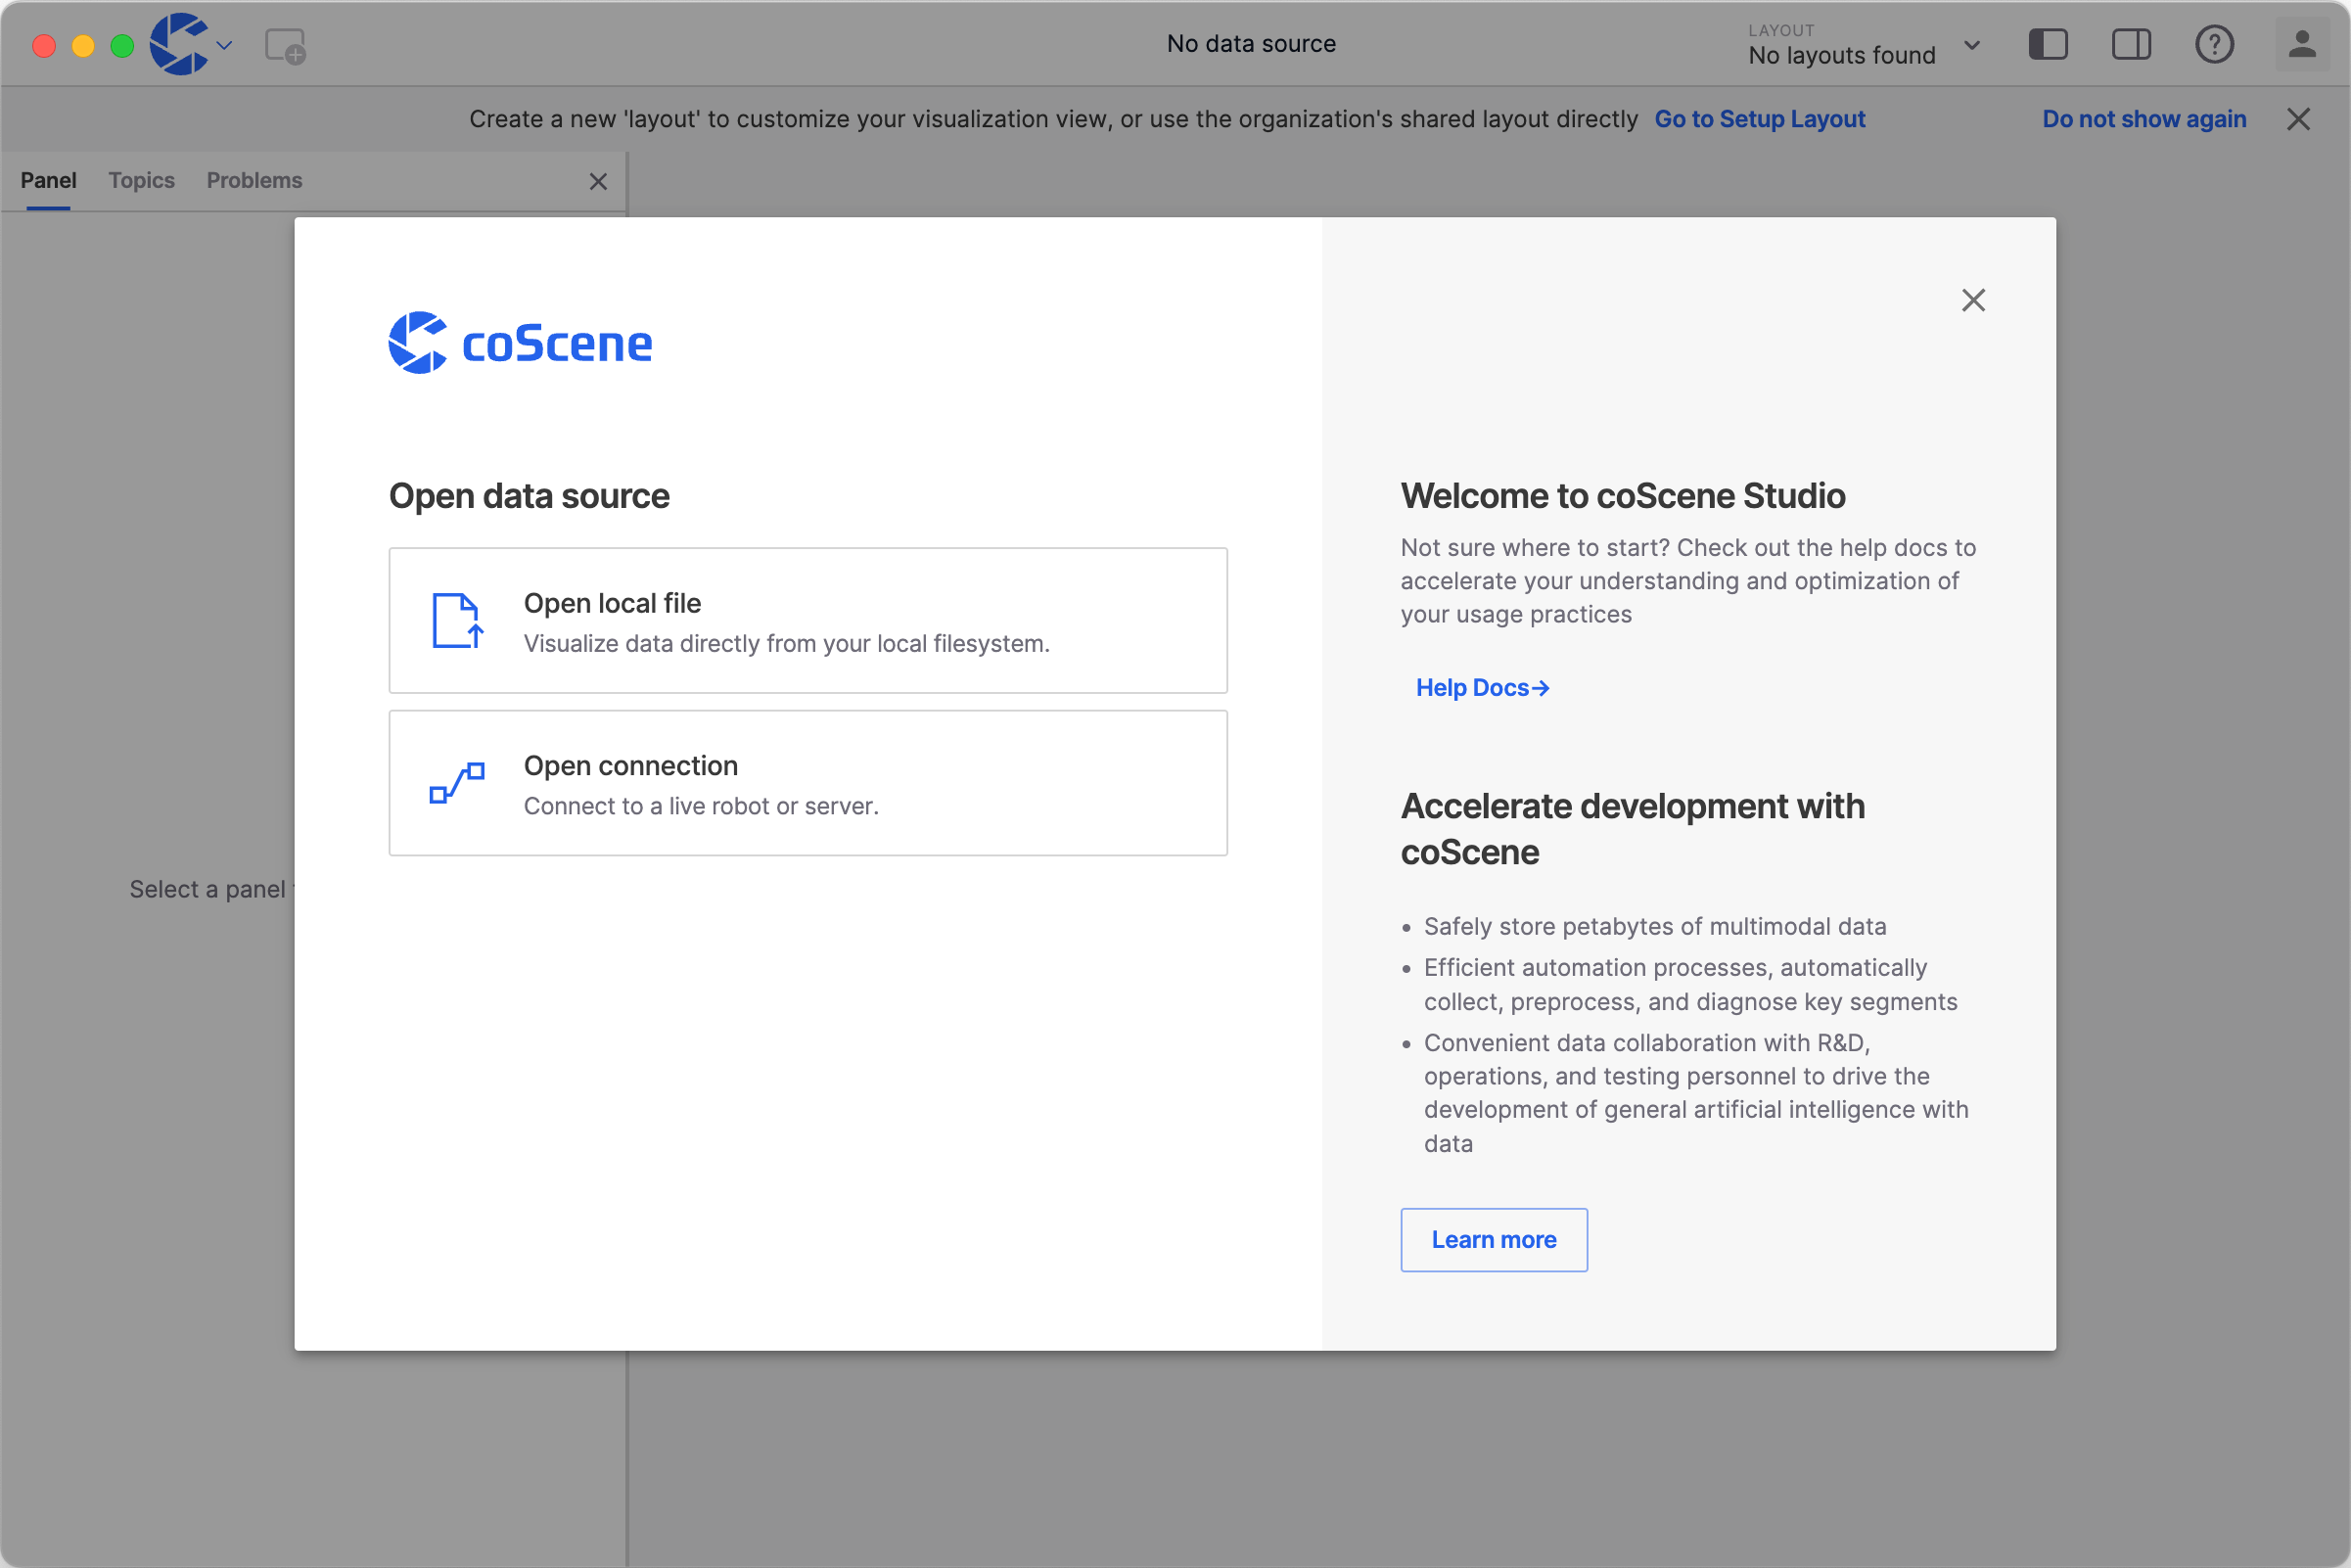
- After launching coStudio, select the "Open Connection" feature.
- Choose the coScene Websocket option and enter the connection address in the WebSocket URL field.
ws://localhost:21274(21274 is the default port for coBridge).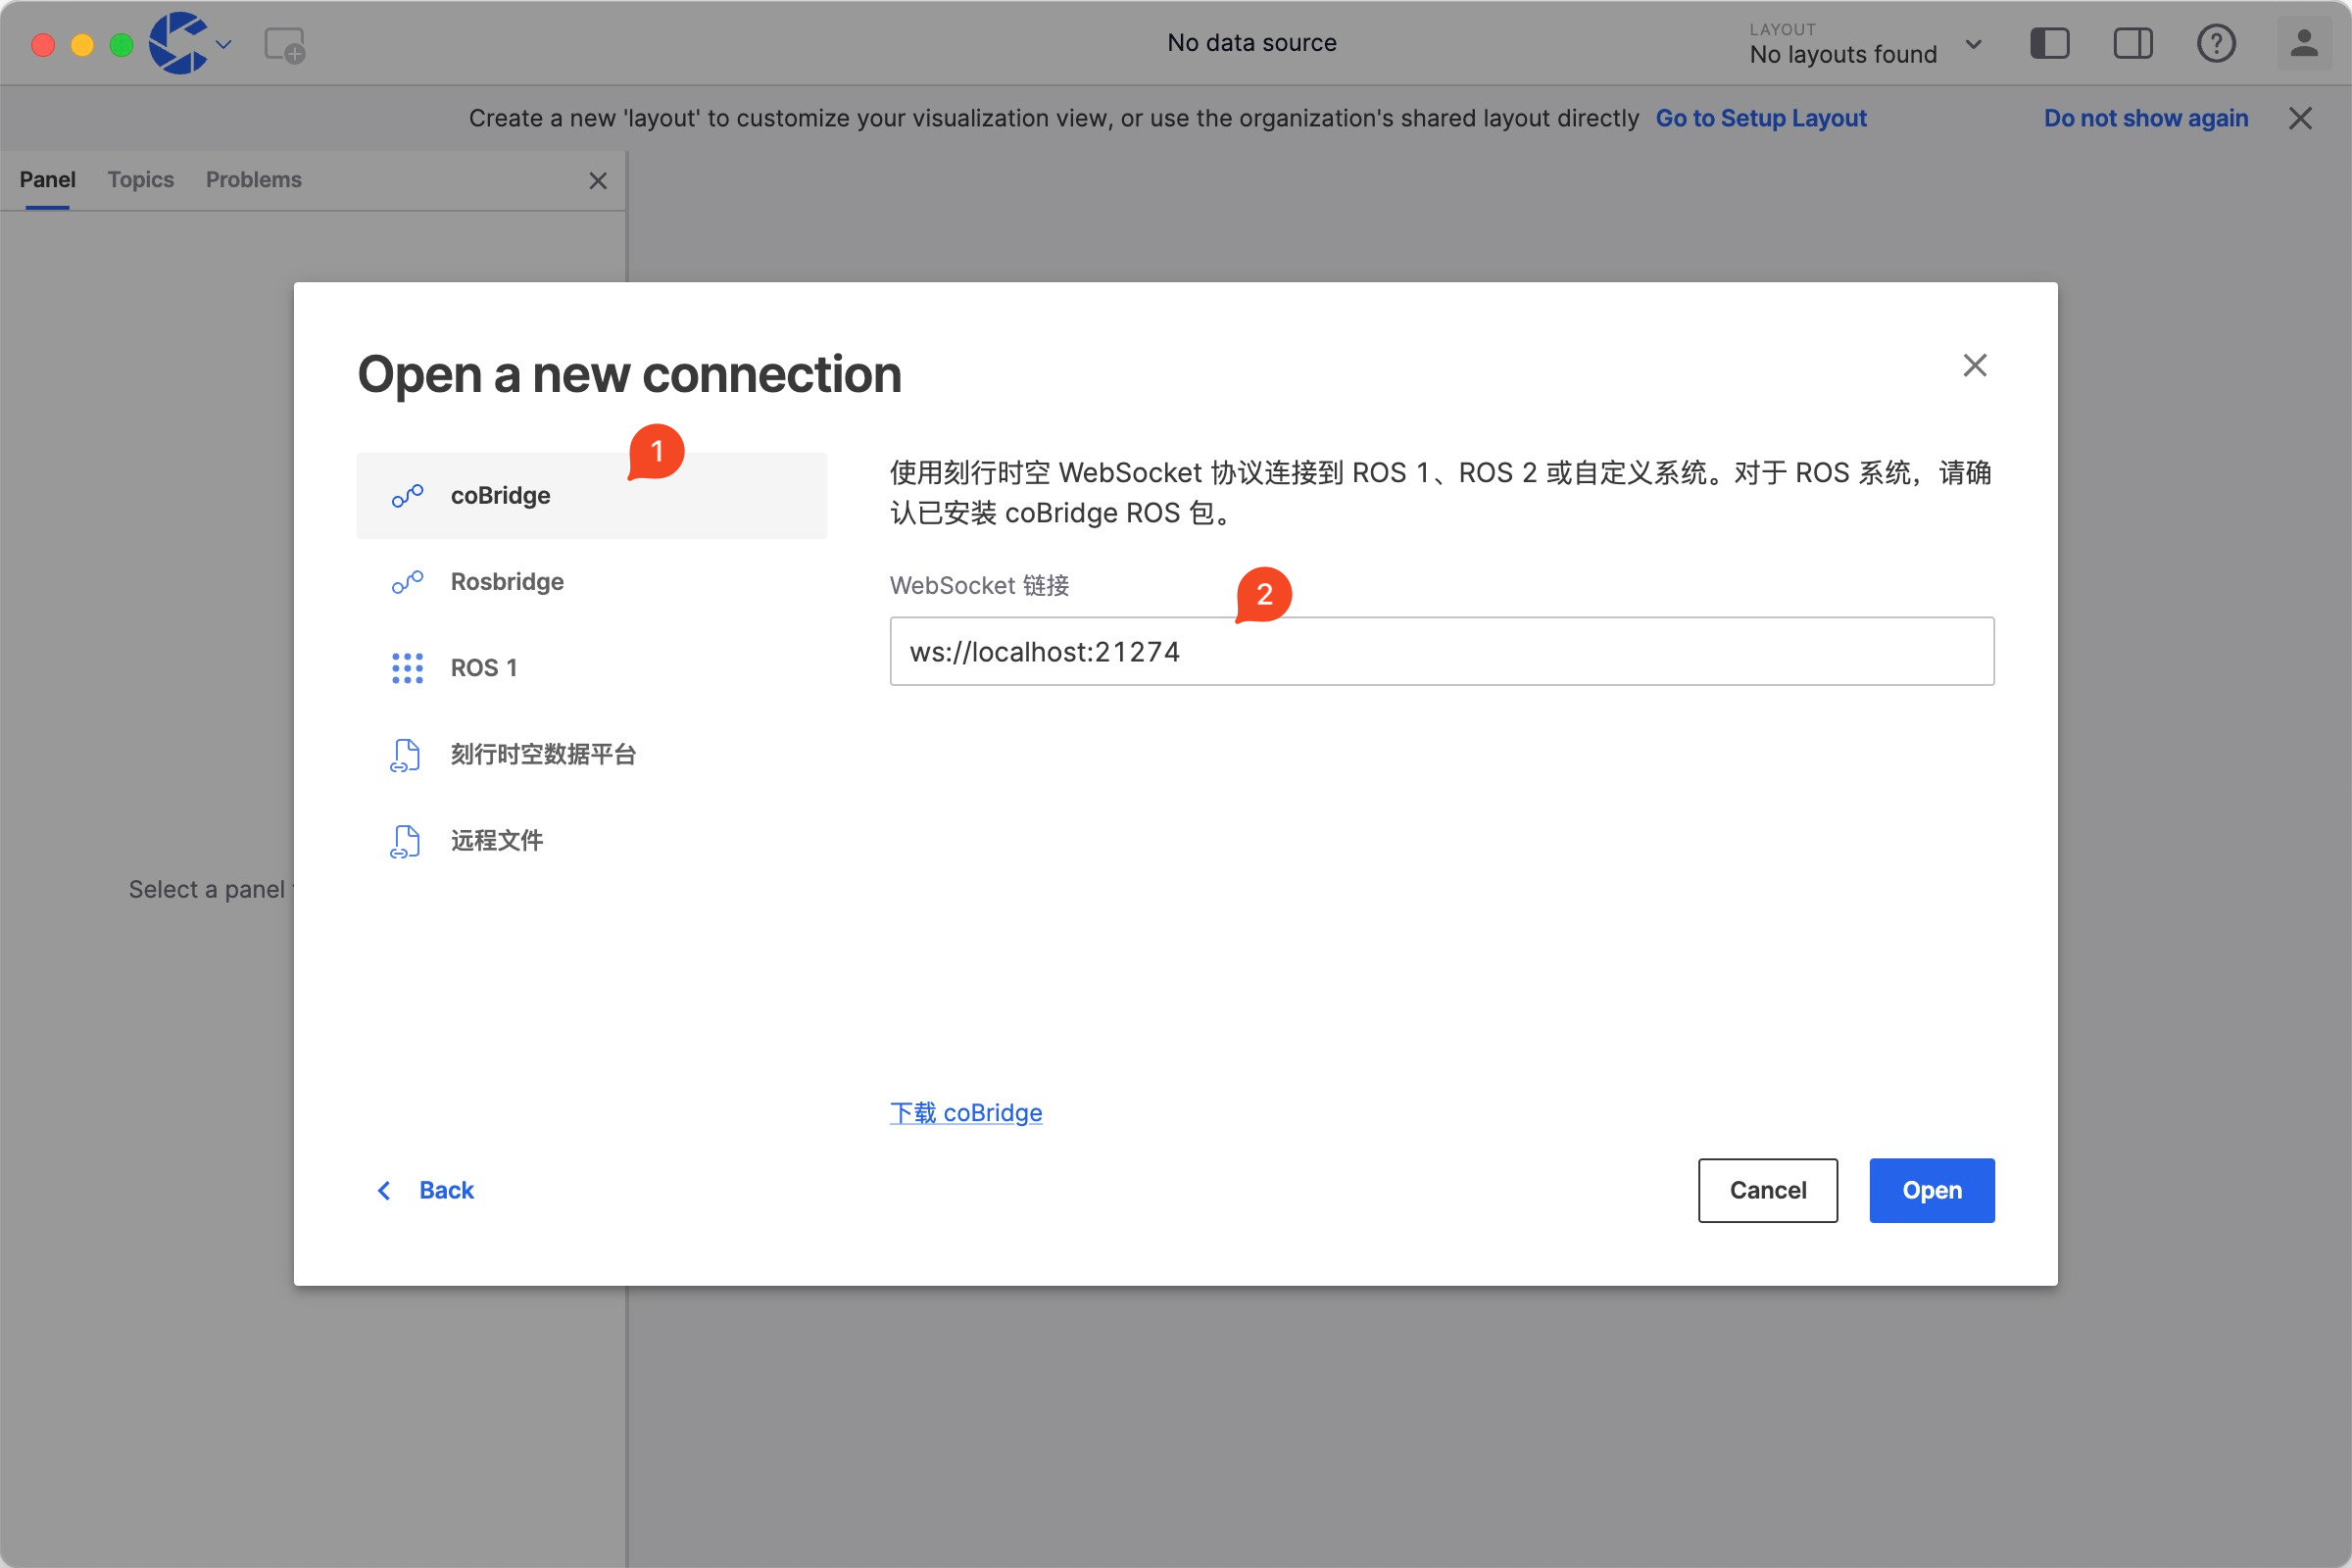
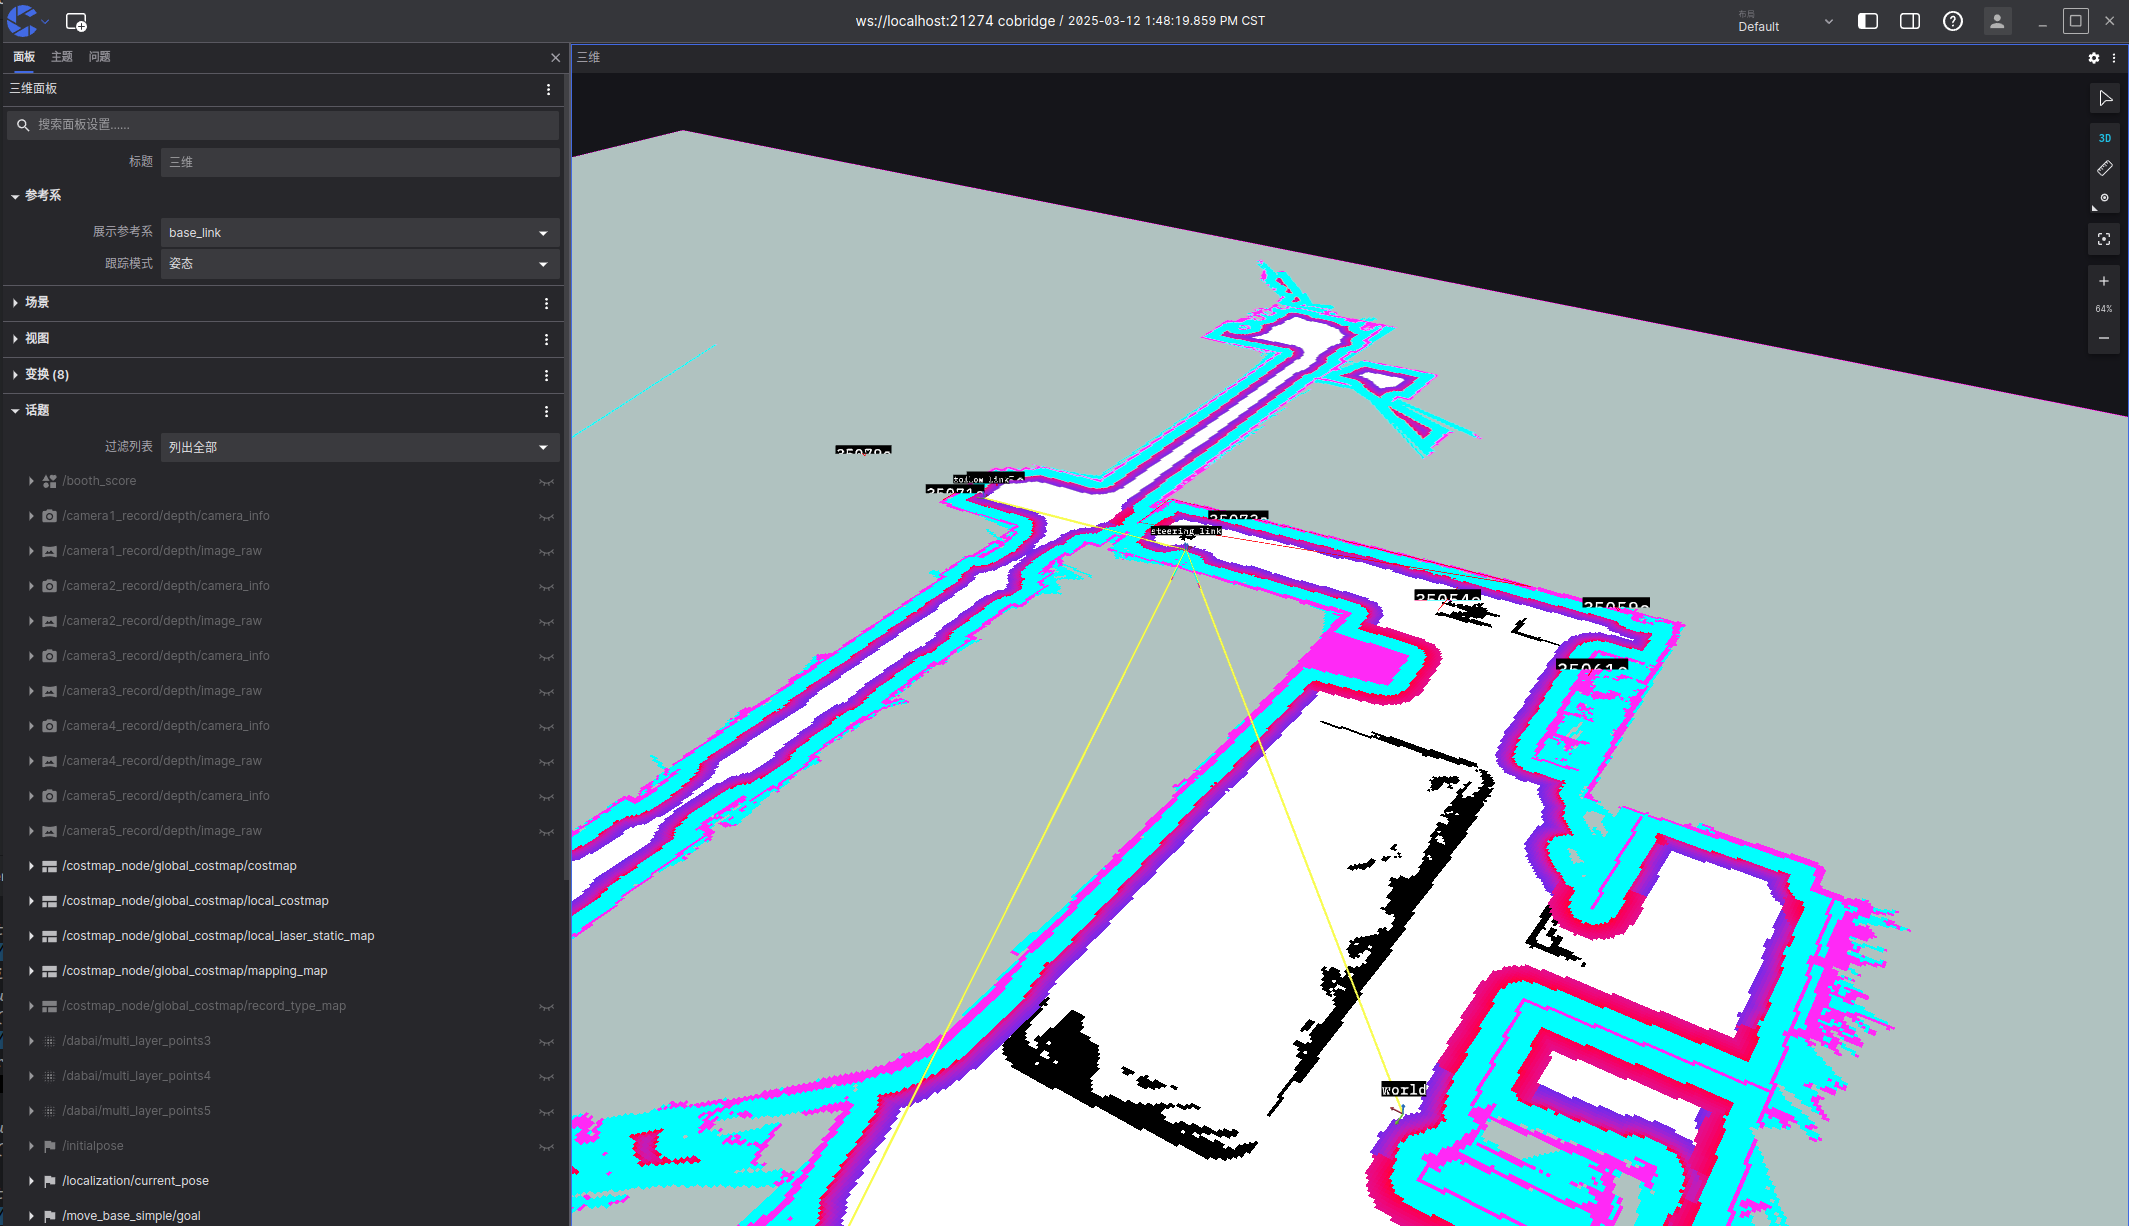
- Once connected, you can use different panels for real-time device data visualization.
Visualization Reference Links
- Panel Settings: Panel Settings
- Layout Settings: Layout